Your Wayve resume, matched to the job ad
Drop in your resume and it opens next to this job, ready to tailor in one click.
4.8 from 167 in-app reviews
Staff Software Engineer - OS, Robot Software
Wayve · Sunnyvale, California USA
Tailor your resume to this job
No account needed to start.
What Wayve asks for
From Wayve's Staff Software Engineer - OS, Robot Software ad, checked 3 Nov 2026.
Embedded systems software
Extensive work with C and C++ to build high-performance system software, particularly for embedded Linux or QNX platforms.
Linux kernel and Yocto
Direct experience with Linux kernels, device trees, and Yocto for configuring distributions and managing boot sequences.
System debugging and diagnostics
Identifying and fixing complex reliability and performance issues using stack traces, core dumps, and analysis of CPU or memory load.
Robotics middleware and IPC
Expertise in inter-process communication mechanisms and middleware designed for high-throughput robotics applications.
Automotive platforms and RTOS
Practical experience with QNX, other real-time operating systems, or specific NVIDIA robotics and automotive platforms.
Wayve offers relocation support and visa sponsorship where applicable. The role is hybrid, combining in-person collaboration at the Sunnyvale office with remote work.
How the example answers the ad
Four of the five requirements above, each matched to a line in the example.
Robotics middleware and IPC
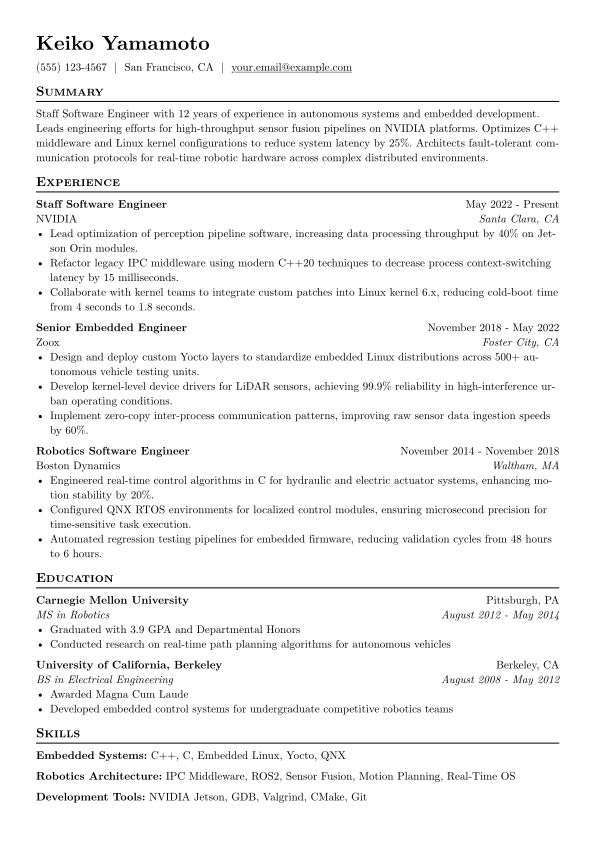
“Refactor legacy IPC middleware using modern C++20 techniques to decrease process context-switching latency by 15 milliseconds.”
Applying C++20 to refactor IPC middleware to lower latency by 15 milliseconds addresses the robotics middleware and IPC requirement.
Linux kernel and Yocto
“Collaborate with kernel teams to integrate custom patches into Linux kernel 6.x, reducing cold-boot time from 4 seconds to 1.8 seconds.”
Integrating custom patches into Linux kernel 6.x to reduce boot times shows the Linux kernel and tooling requirement.
Automotive platforms and RTOS
“Configured QNX RTOS environments for localized control modules, ensuring microsecond precision for time-sensitive task execution.”
Configuring QNX RTOS for control modules requiring microsecond precision shows the automotive platforms and RTOS requirement.
Embedded systems software
“Engineered real-time control algorithms in C for hydraulic and electric actuator systems, enhancing motion stability by 20%.”
Using C to engineer real-time algorithms for actuator systems shows the embedded systems software requirement.
The whole example as text
Keiko Yamamoto · Staff Software Engineer
Summary
Staff Software Engineer with 12 years of experience in autonomous systems and embedded development. Leads engineering efforts for high-throughput sensor fusion pipelines on NVIDIA platforms. Optimizes C++ middleware and Linux kernel configurations to reduce system latency by 25%. Architects fault-tolerant communication protocols for real-time robotic hardware across complex distributed environments.
Experience
Staff Software Engineer · NVIDIA
Santa Clara, CA · 2022 - Present
- Lead optimization of perception pipeline software, increasing data processing throughput by 40% on Jetson Orin modules.
- Refactor legacy IPC middleware using modern C++20 techniques to decrease process context-switching latency by 15 milliseconds.
- Collaborate with kernel teams to integrate custom patches into Linux kernel 6.x, reducing cold-boot time from 4 seconds to 1.8 seconds.
Senior Embedded Engineer · Zoox
Foster City, CA · 2018 - 2022
- Design and deploy custom Yocto layers to standardize embedded Linux distributions across 500+ autonomous vehicle testing units.
- Develop kernel-level device drivers for LiDAR sensors, achieving 99.9% reliability in high-interference urban operating conditions.
- Implement zero-copy inter-process communication patterns, improving raw sensor data ingestion speeds by 60%.
Robotics Software Engineer · Boston Dynamics
Waltham, MA · 2014 - 2018
- Engineered real-time control algorithms in C for hydraulic and electric actuator systems, enhancing motion stability by 20%.
- Configured QNX RTOS environments for localized control modules, ensuring microsecond precision for time-sensitive task execution.
- Automated regression testing pipelines for embedded firmware, reducing validation cycles from 48 hours to 6 hours.
Education
MS in Robotics · Carnegie Mellon University
Pittsburgh, PA · 2012 - 2014
- Graduated with 3.9 GPA and Departmental Honors
- Conducted research on real-time path planning algorithms for autonomous vehicles
BS in Electrical Engineering · University of California, Berkeley
Berkeley, CA · 2008 - 2012
- Awarded Magna Cum Laude
- Developed embedded control systems for undergraduate competitive robotics teams
Skills
Frequently asked questions
Is the example from an employee?
No. It is an AI-written example for this ad, made to show how a resume can answer it.
Do I need to meet every requirement to apply?
No. The ad encourages you to apply even if you do not tick every box, provided you are passionate about autonomy and eager to learn.
What is the working environment like?
It is a hybrid model involving both in-person work at a hub and remote time. The ad notes the company is not a mature, settled structure and suits people who want real ownership.
Where do I apply?
On the official Wayve posting, through the job link on this page.
What happens when I tailor my resume here?
Your resume opens in the editor next to this job. Tailor it in one click, then keep or discard the edits. You only need an account to download.